From the poster
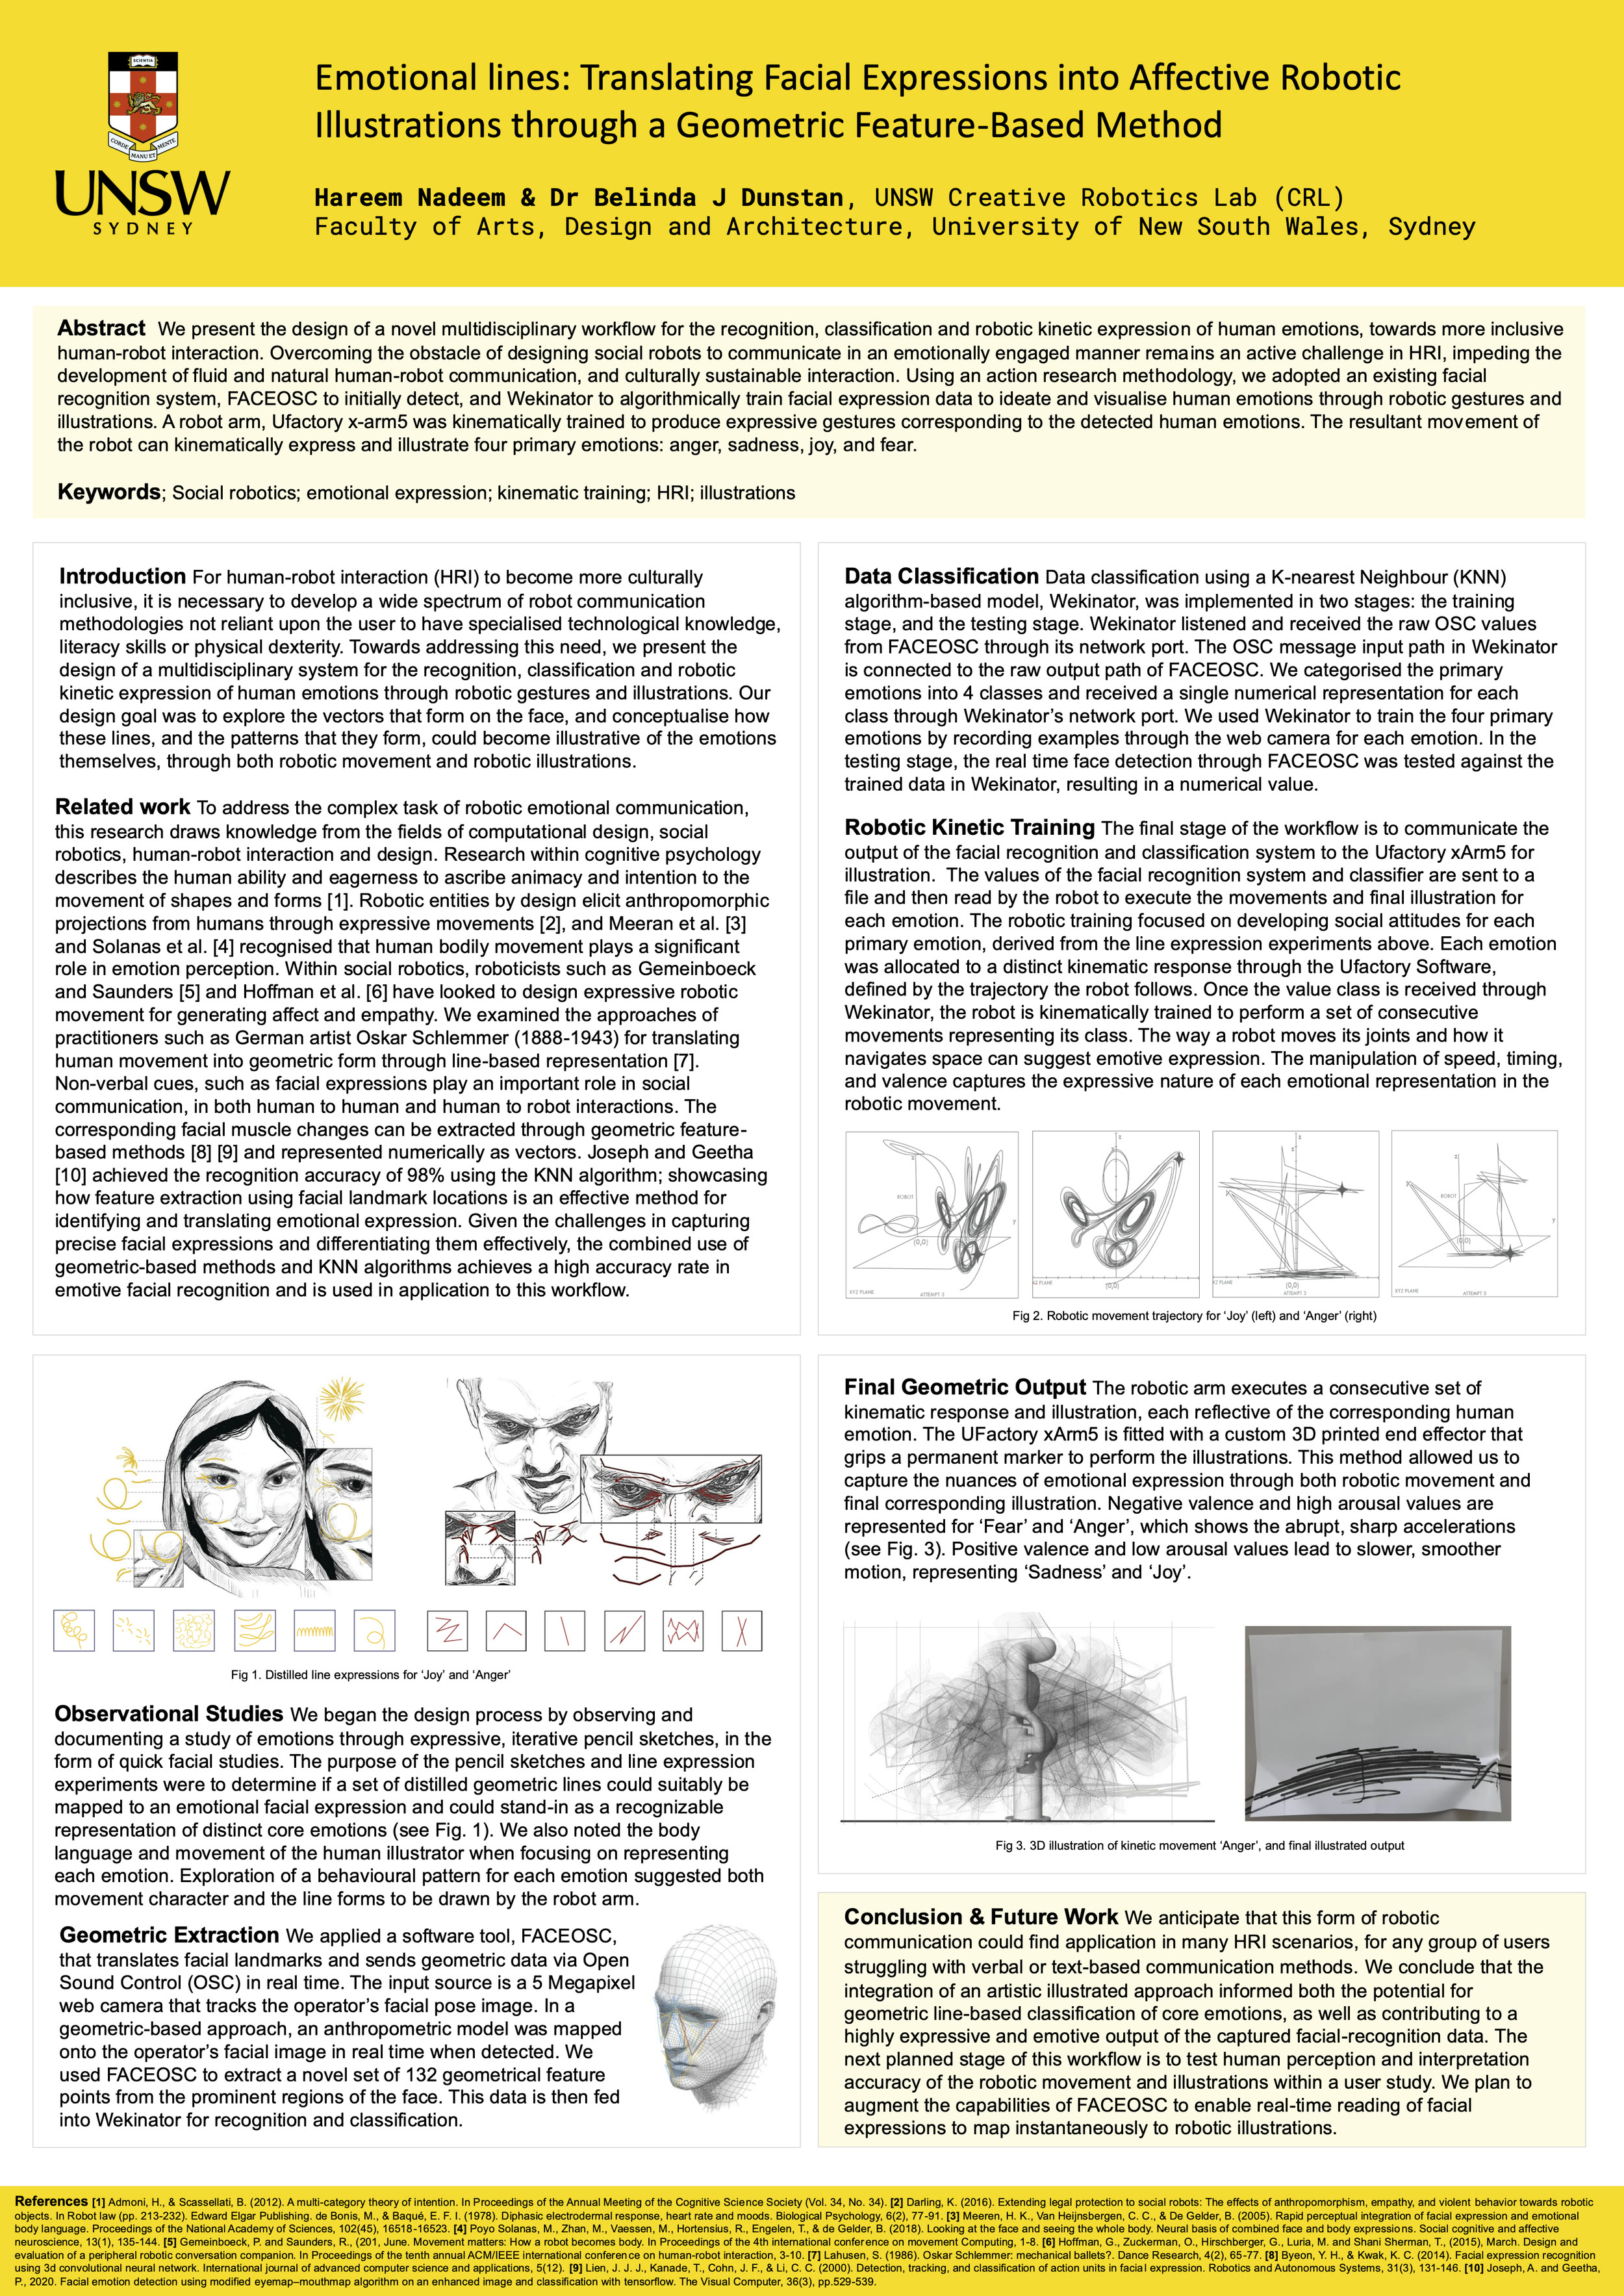
We present the design of a novel multidisciplinary workflow for the recognition, classification and robotic kinetic expression of human emotions, towards more inclusive human-robot interaction. Overcoming the obstacle of designing social robots to communicate in an emotionally engaged manner remains an active challenge in HRI, impeding the development of fluid and natural human-robot communication, and culturally sustainable interaction. Using an action research methodology, we adopted an existing facial recognition system, FACEOSC to initially detect, and Wekinator to algorithmically train facial expression data to ideate and visualise human emotions through robotic gestures and illustrations. A robot arm, Ufactory x-arm5 was kinematically trained to produce expressive gestures corresponding to the detected human emotions. The resultant movement of the robot can kinematically express and illustrate four primary emotions: anger, sadness, joy, and fear.