From the poster
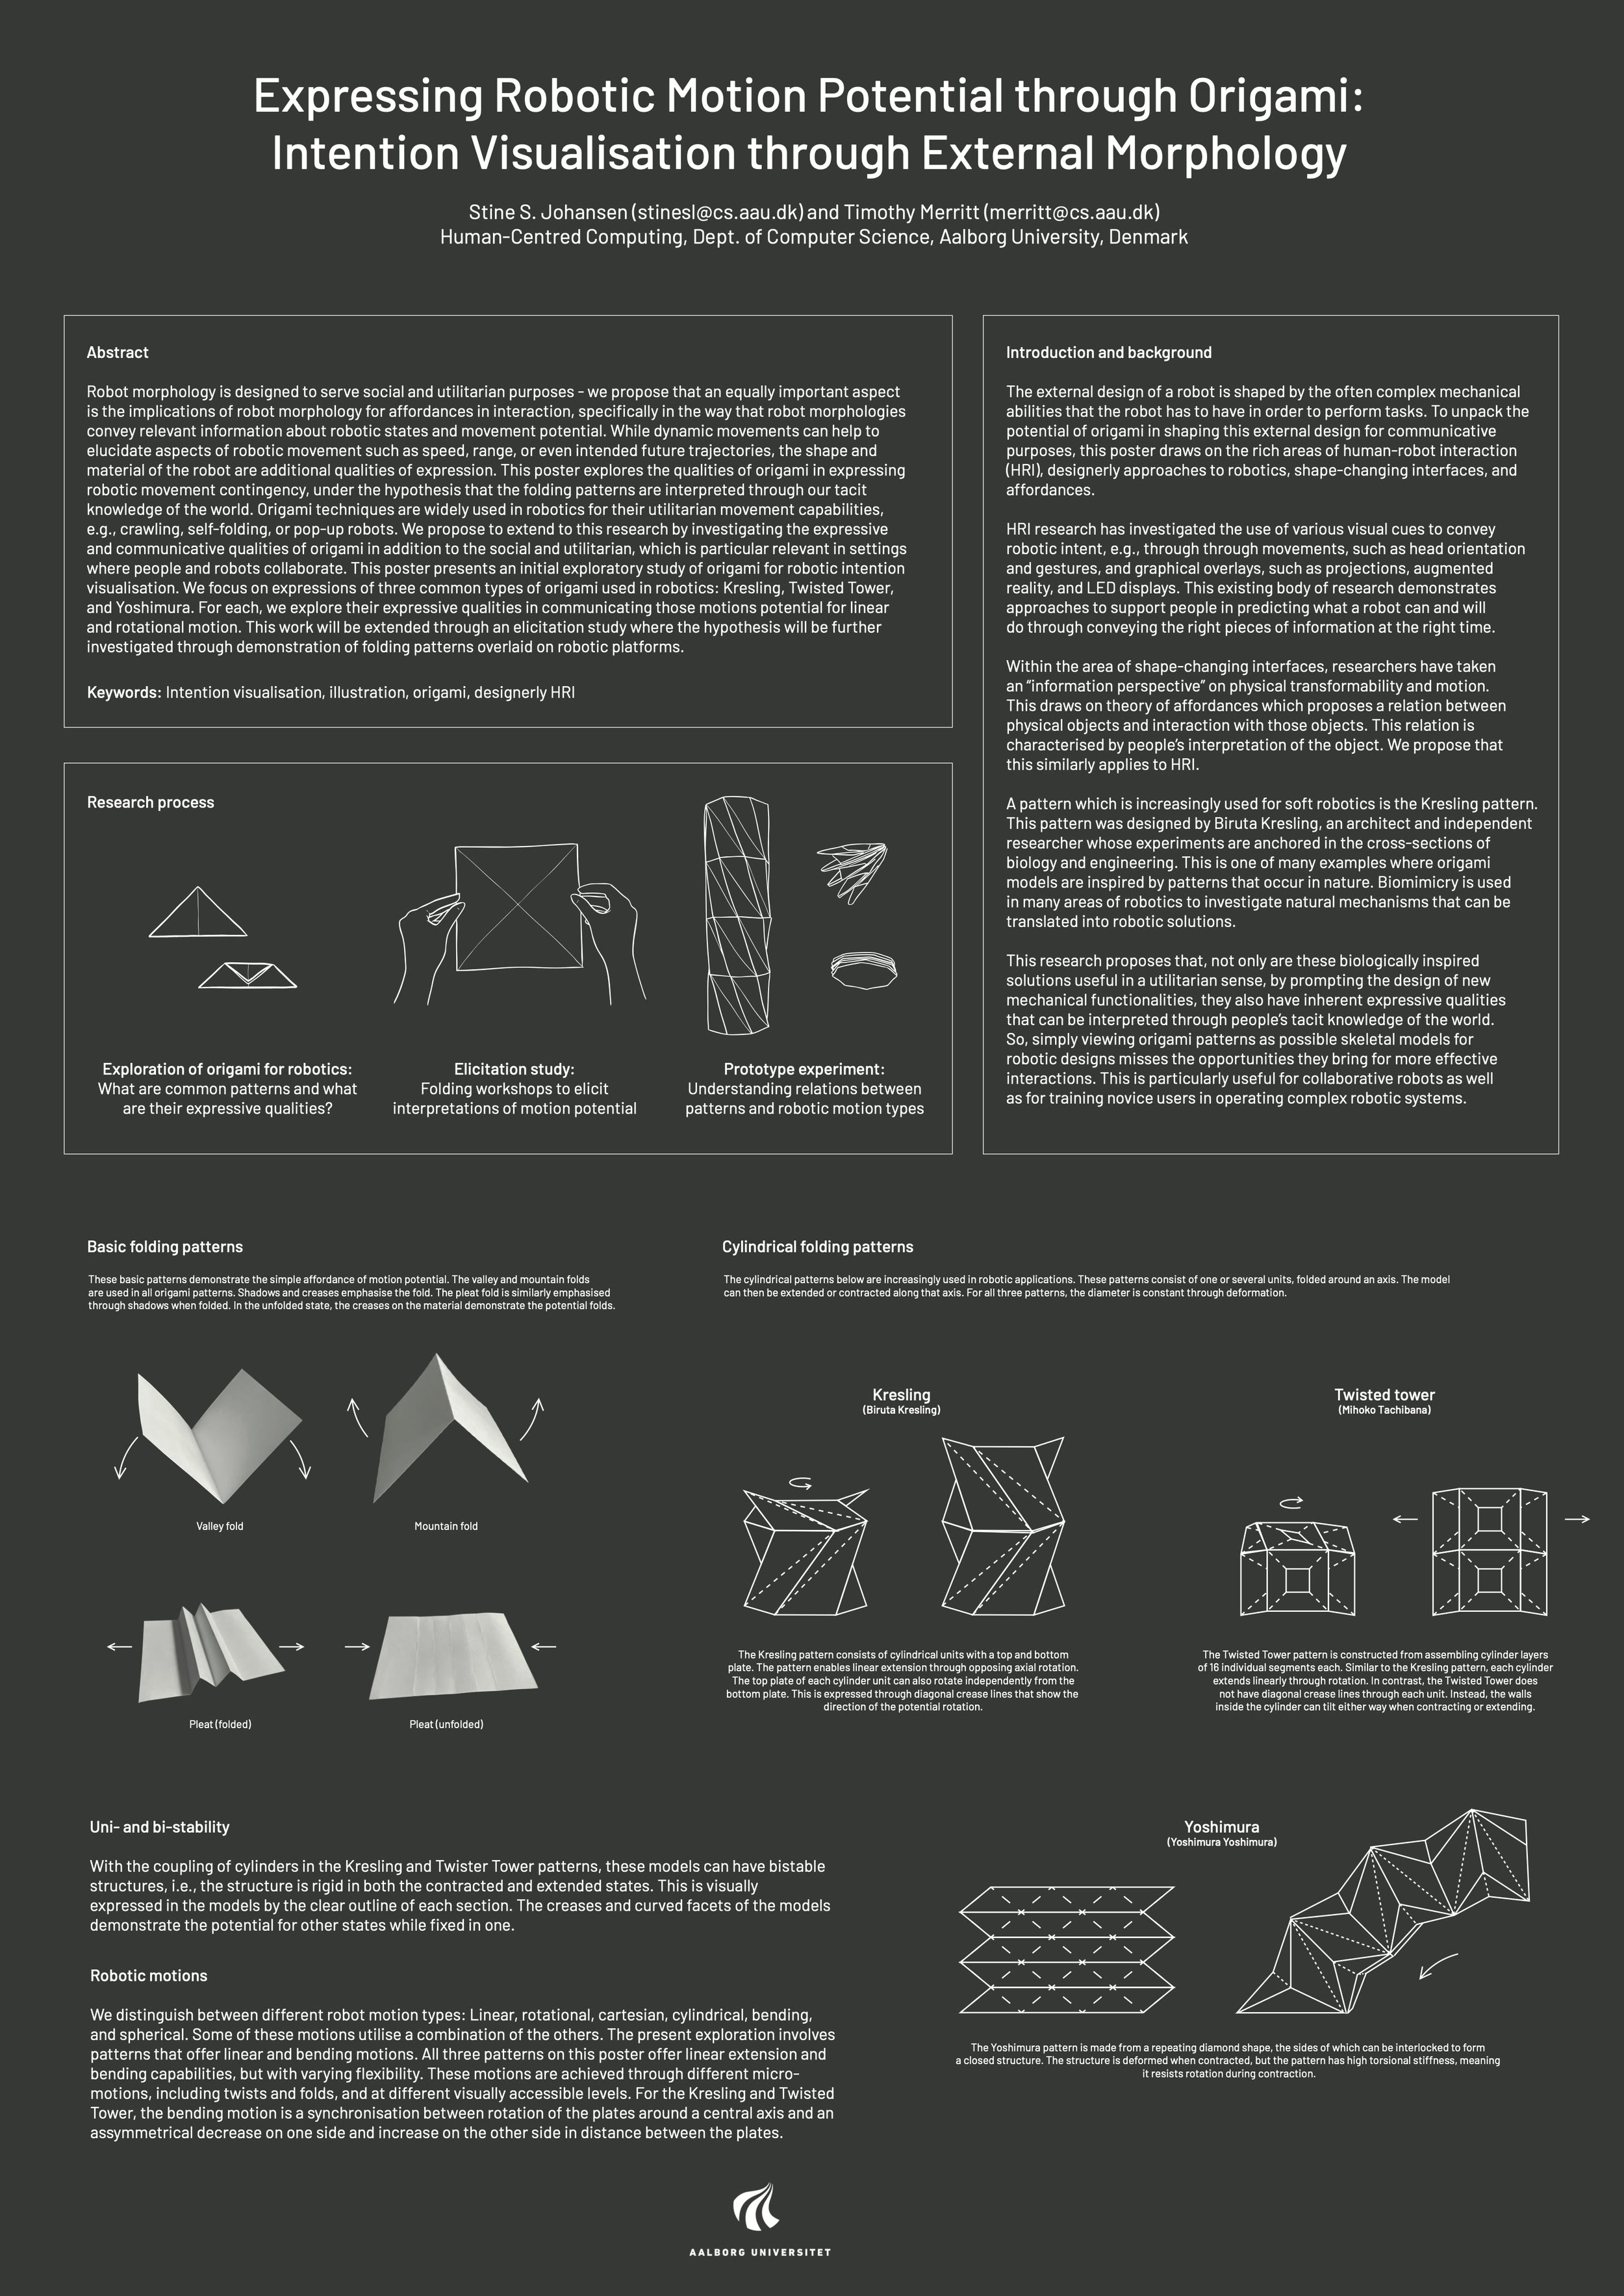
Robot morphology is designed to serve social and utilitarian purposes – we propose that an equally important aspect is the implications of robot morphology for affordances in interaction, specifically in the way that robot morphologies convey relevant information about robotic states and movement potential. While dynamic movements can help to elucidate aspects of robotic movement such as speed, range, or even intended future trajectories, the shape and material of the robot are additional qualities of expression. This poster explores the qualities of origami in expressing robotic movement contingency, under the hypothesis that the folding patterns are interpreted through our tacit knowledge of the world. Origami techniques are widely used in robotics for their utilitarian movement capabilities, e.g., crawling, self-folding, or pop-up robots. We propose to extend to this research by investigating the expressive and communicative qualities of origami in addition to the social and utilitarian, which is particular relevant in settings where people and robots collaborate. This poster presents an initial exploratory study of origami for robotic intention visualisation. We focus on expressions of three common types of origami used in robotics: Kresling, Twisted Tower, and Yoshimura. For each, we explore their expressive qualities in communicating those motions potential for linear and rotational motion. This work will be extended through an elicitation study where the hypothesis will be further investigated through demonstration of folding patterns overlaid on robotic platforms.